A Careful Examination of Large Behavior Models for Multitask Dexterous Manipulation
Recommended to me by Krish Mehta.
Project page:
They look at different scaling laws for robotics.
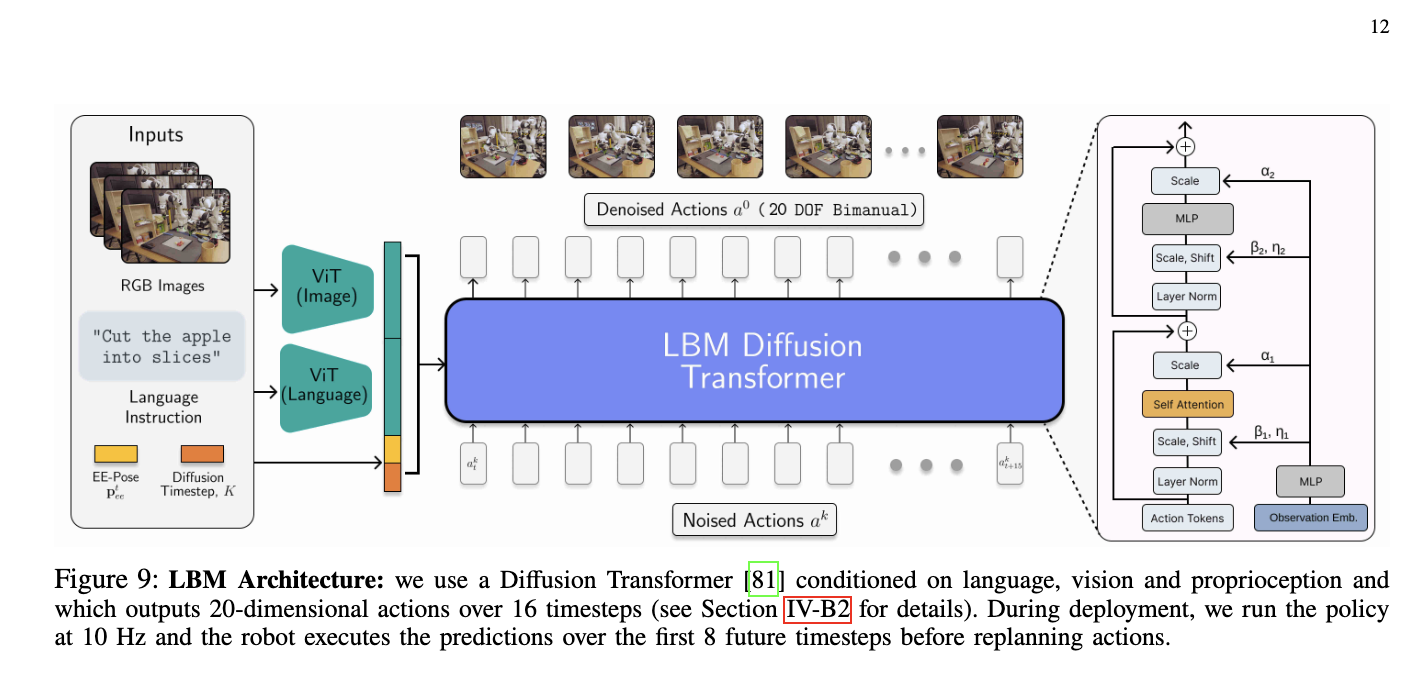
- Uses a Diffusion Transformer
Takeaways:
- Robotics is extremely noisy, in this paper, they use statistical rigor to get conclusive results
- Some talks on normalization
Citation
(Team et al., 2025)
Team, T. L., Barreiros, J., Beaulieu, A., Bhat, A., Cory, R., Cousineau, E., Dai, H., Fang, C.-H., Hashimoto, K., Irshad, M. Z., Itkina, M., Kuppuswamy, N., Lee, K.-H., Liu, K., McConachie, D., McMahon, I., Nishimura, H., Phillips-Grafflin, C., Richter, C., … Tedrake, R. (2025). A Careful Examination of Large Behavior Models for Multitask Dexterous Manipulation. https://arxiv.org/pdf/2507.05331