pi0.5
“How can we enable better generalization?” - By training on many surrogate tasks
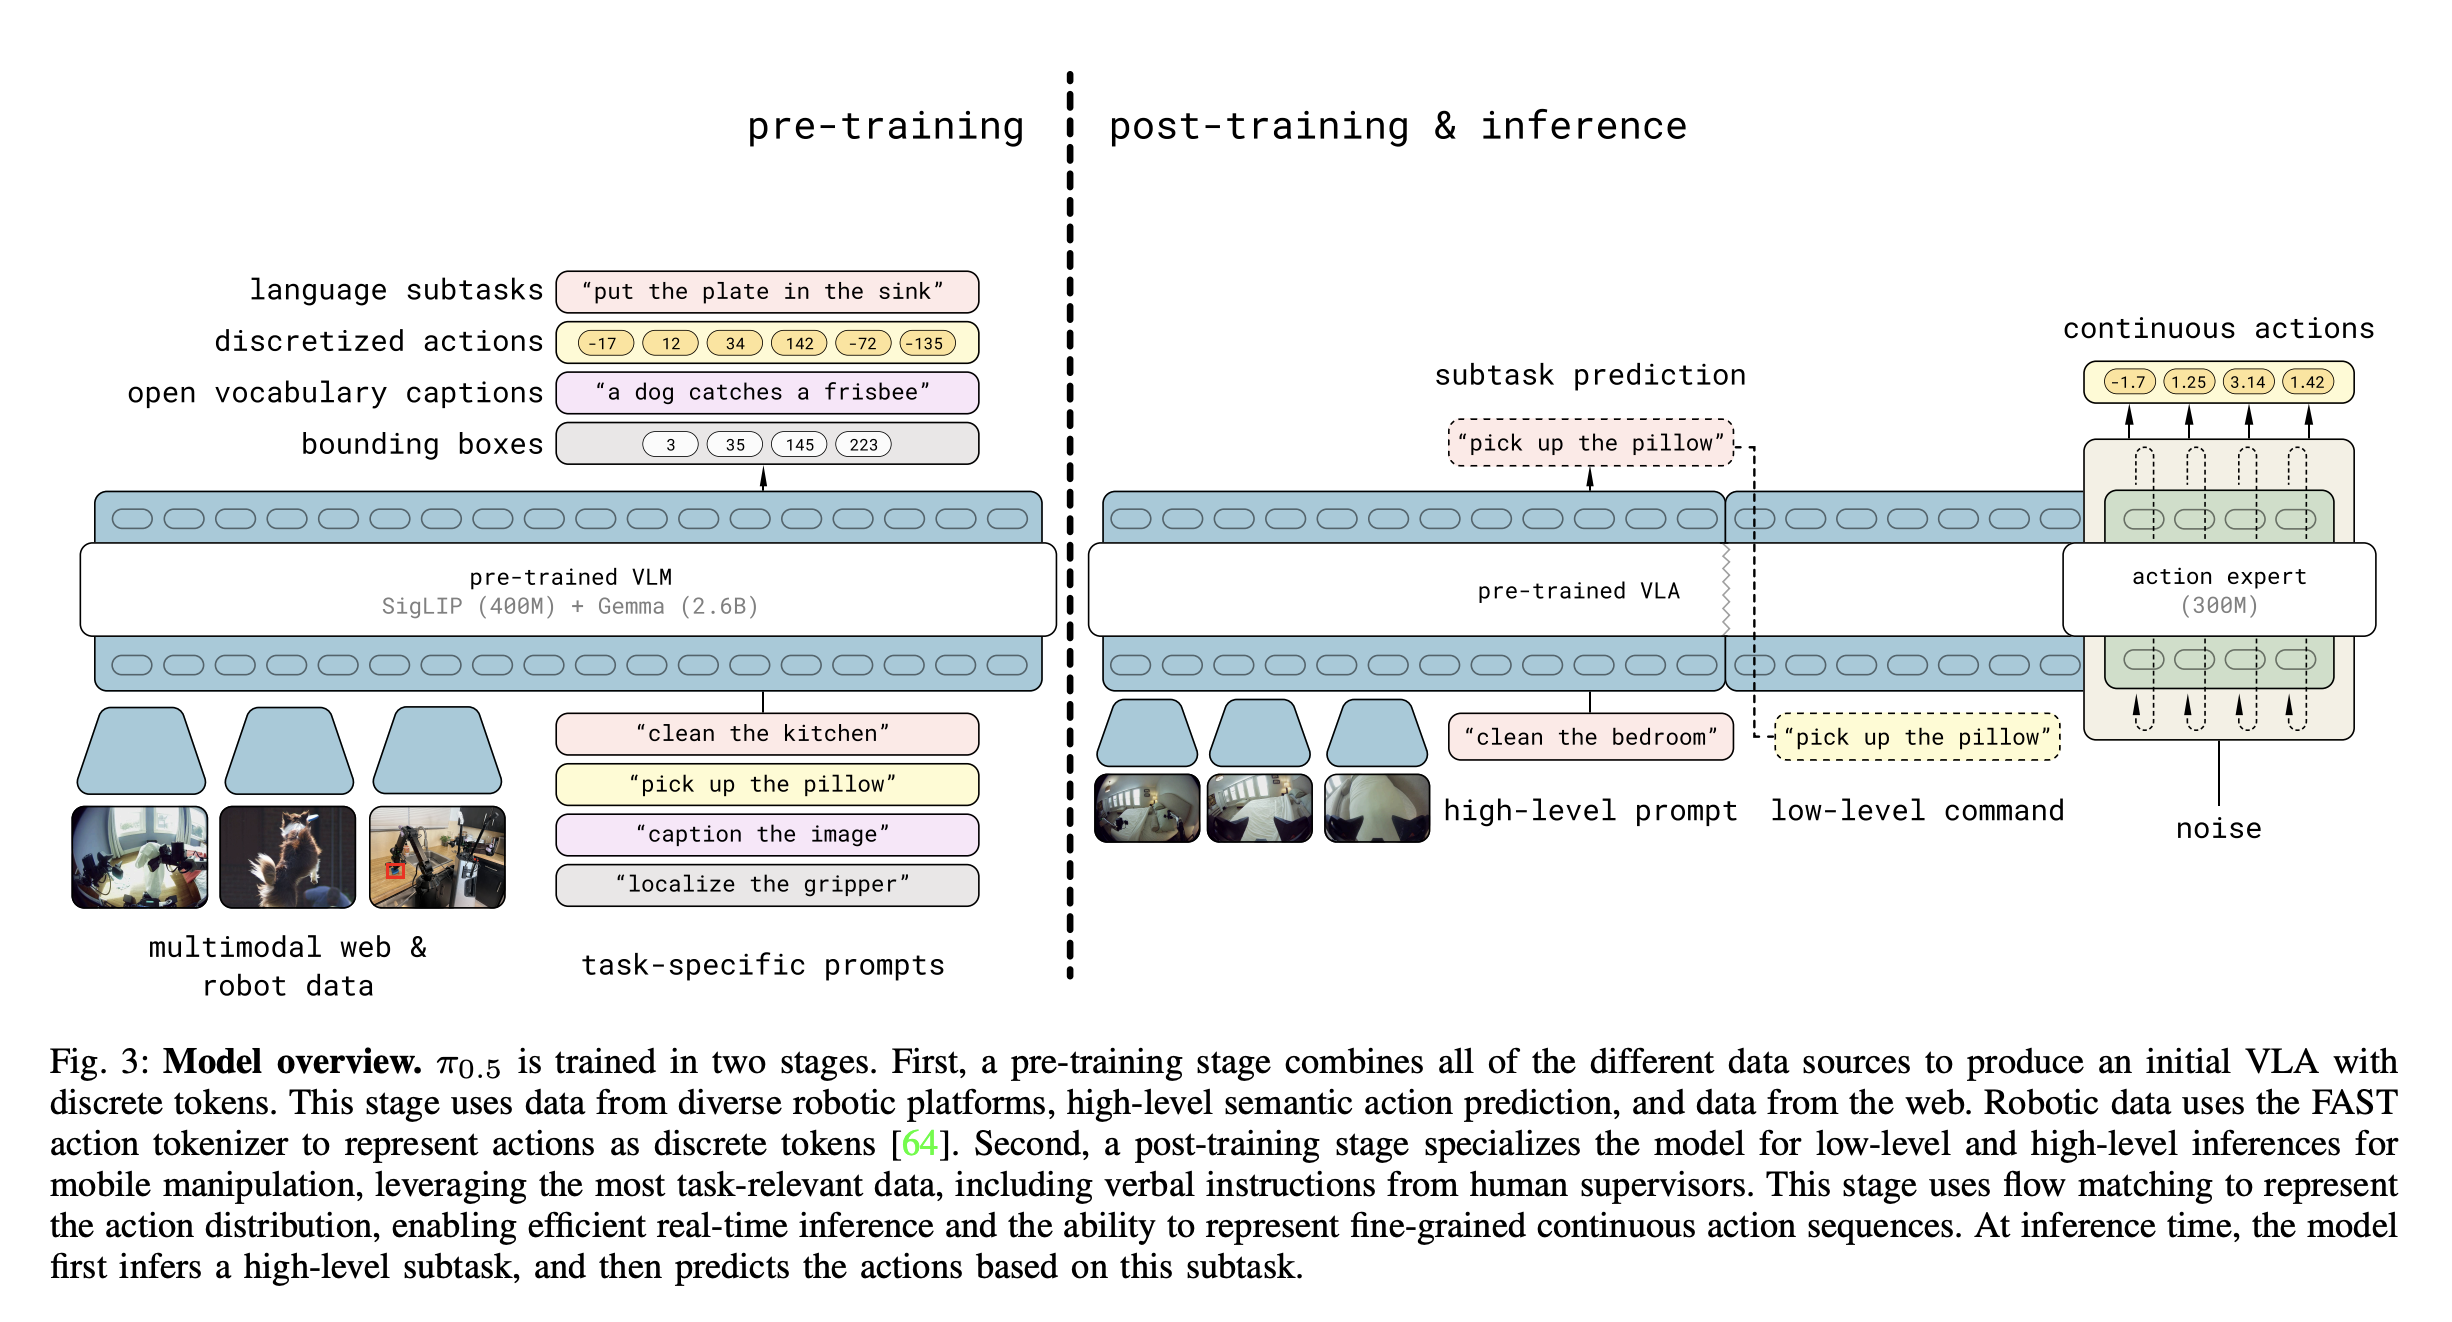
Training in Lerobot
  python src/lerobot/scripts/lerobot_train.py \
      --dataset.repo_id=Gongsta/koch-tshirt-folding-v3 \
      --dataset.video_backend=pyav \
      --policy.type=pi05 \
      --output_dir=./outputs/pi05_training \
      --job_name=pi05_training \
      --policy.repo_id="Gongsta/pi05-koch-tshirt" \
      --policy.pretrained_path=lerobot/pi05_base \
      --policy.compile_model=true \
      --policy.gradient_checkpointing=true \
      --wandb.enable=true \
      --policy.dtype=bfloat16 \
      --policy.freeze_vision_encoder=false \
      --policy.train_expert_only=false \
      --steps=6000 \
      --save_freq=2000 \
      --policy.device=cuda \
      --batch_size=32 \
      --num_workers=4
python src/lerobot/scripts/lerobot_train.py\
    --dataset.repo_id=Gongsta/koch-tshirt-folding-v3 \
    --policy.type=pi05 \
    --output_dir=./outputs/pi05_training \
    --job_name=pi05_training \
  --policy.repo_id="Gongsta/pi05-koch-tshirt" \
    --policy.pretrained_path=lerobot/pi05_base \
    --policy.compile_model=true \
    --policy.gradient_checkpointing=true \
    --wandb.enable=true \
    --policy.dtype=bfloat16 \
    --policy.freeze_vision_encoder=false \
    --policy.train_expert_only=false \
    --steps=6000 \
    --save_freq=2000 \
    --policy.device=cuda \
    --batch_size=32
Citation
(Intelligence et al., 2025)
Intelligence, P., Black, K., Brown, N., Darpinian, J., Dhabalia, K., Driess, D., Esmail, A., Equi, M., Finn, C., Fusai, N., Galliker, M. Y., Ghosh, D., Groom, L., Hausman, K., Ichter, B., Jakubczak, S., Jones, T., Ke, L., LeBlanc, D., … Zhilinsky, U. (2025). π0.5: a Vision-Language-Action Model with Open-World Generalization. https://arxiv.org/pdf/2504.16054