Learning Fine-Grained Bimanual Manipulation with Low-Cost Hardware (ALOHA)
Led by Mr. Tony Zhao.
- https://tonyzhaozh.github.io/aloha/
- https://mobile-aloha.github.io/
- https://aloha-2.github.io/
- https://aloha-unleashed.github.io/
Papers
Related
Main contributions of the paper:
- Introducing the concept of action chunking to reduce the compounding error problem
“Addressing compounding errors. A major shortcoming of BC is compounding errors, where errors from previous timesteps accumulate and cause the robot to drift off of its training distribution, leading to hard-to-recover states”
- This is due to the autoregressive nature of the models

- So the trajectory goes more and more out of distribution
That’s why Action chunking can help, so it reduces the effective horizon of the task by “k”-fold.
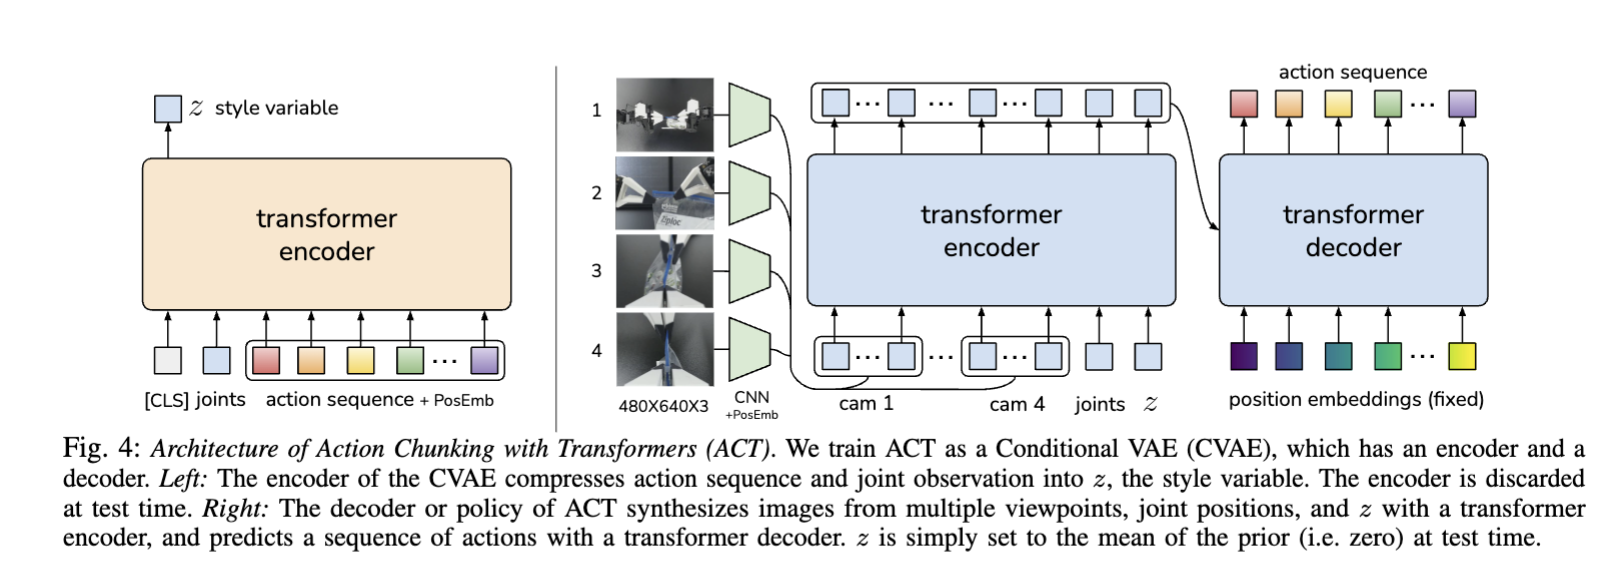
ACT is trained as a cVAE
Links
Resources
So what is action chunking? Action chunking is a technique in robotics and imitation learning where, instead of predicting and executing one action at a time, a robot forecasts and carries out a sequence of actions—referred to as a “chunk”—based on its current observation.
Benefits of action chunking (reference blog):
- Allows your model to control your robot at a much higher frequency given a large model
- You of course don’t get the reactivity, but that’s a bonus
- Better temporal consistency without having to do Proprioceptive History
“Generally, the more information is contained in the observation space, the more likely causal confusion will happen for imitation learning.”
Related
Citation
(Zhao et al., 2023)